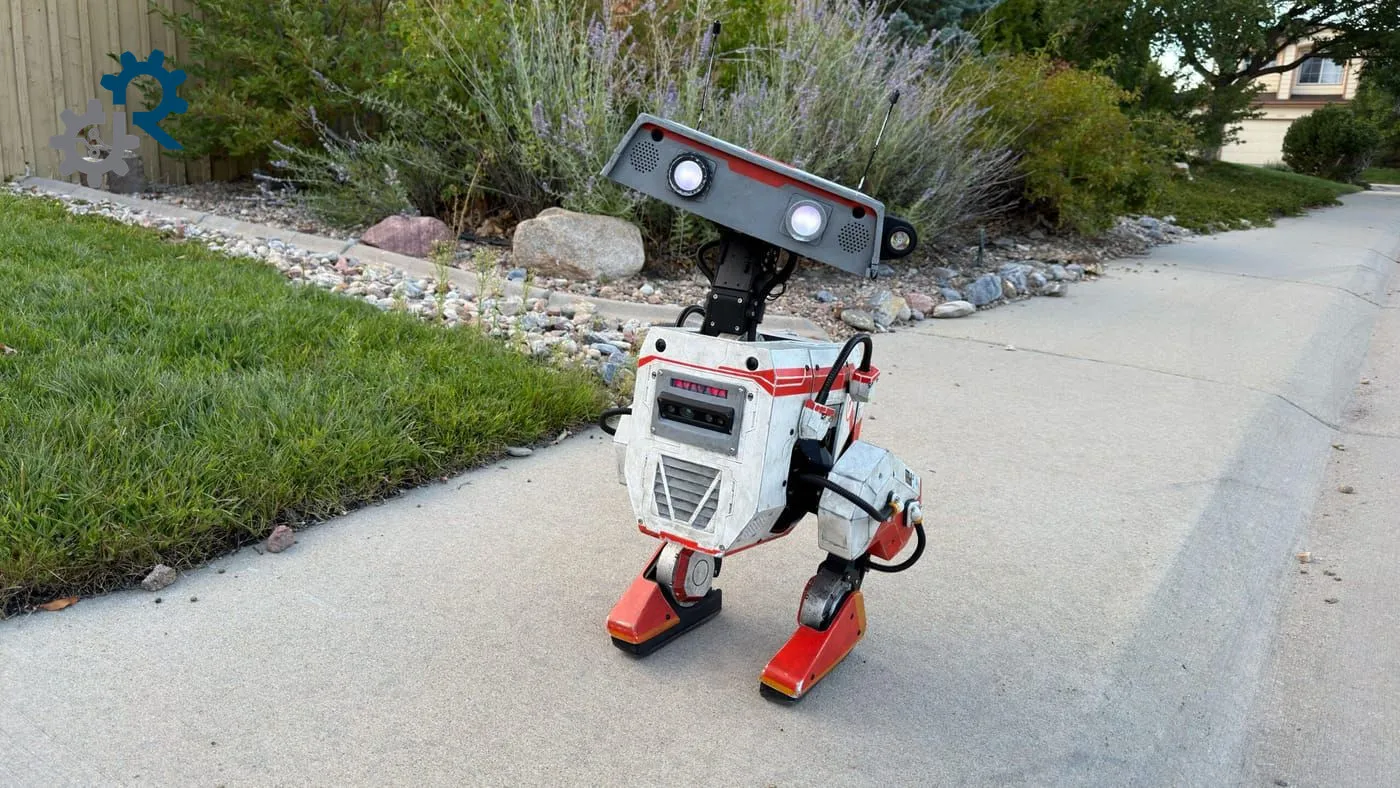
OpenBDX, an open-source walking duck robot, has 25 builds under way
Image: Jaime Machuca / OpenBDX, via Make: · press-kit
Make: profiles OpenBDX, an open build of a duck-style bipedal robot whose site has more than 1,300 verified users and at least 25 robots in progress.
OpenBDX, an open-source bipedal robot styled after a small walking duck, is the subject of a Make: article published on 30 October 2026 and written by the project's founder, Denver engineer Jaime Machuca. Since openbdx.org opened on 2 September, it has drawn more than 1,300 registered, verified users, and at least 25 ducks are being built around the world. Builders sign in with GitHub to get the files and the build guide.
Each leg has five degrees of freedom, and the head and neck add four more plus two antenna servos; the walking policy drives 14 joints. Two Nvidia Jetson Orin NX modules, one in the chest and one in the head, share the work. Walking is learned with reinforcement learning in simulation, mainly MJLab with PPO, using animation references, pushes, rough terrain and domain randomization, and the policies are exported to ONNX to run on the robot. Mimir Reynisson led much of the hardware, firmware and training, and Florian Bieregger redesigned the CNC leg parts.
The article gives no build cost. The project shows how sim-to-real legged locomotion, once a research-lab capability, is now within reach of a hobbyist community.
Sources
- Make: Primary source