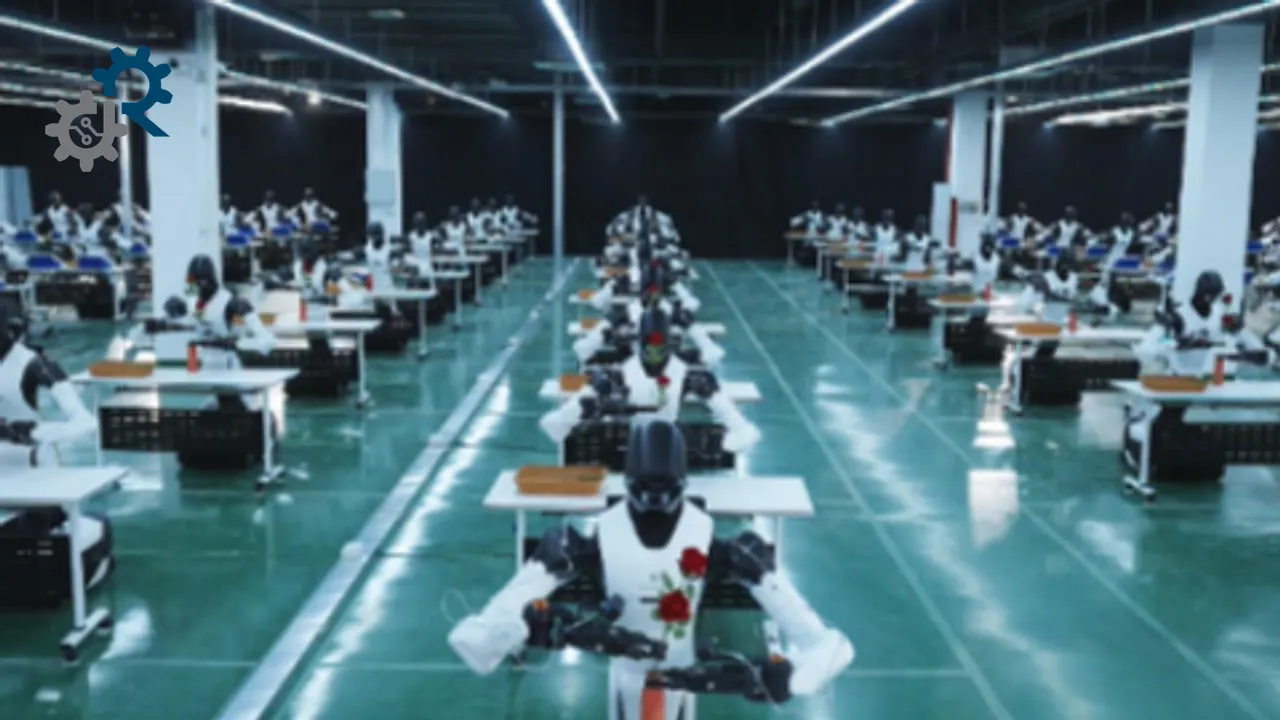
A preprint trains 96 real robots on pooled experience and lifts phone packaging to 98.3%
Image: Yu et al., arXiv 2610.25736 (CC BY 4.0) · cc-by
A 44-author arXiv preprint posted on 19 October 2026 reports a fleet of 96 robots sharing execution data to improve one policy.
A 44-author preprint posted to arXiv on 19 October 2026, with a second version on 21 October, describes Collective Experience Learning, a method in which deployed robots pool their own execution experience to update a shared policy. It aims to reduce reliance on expert corrections and needs no additional expert demonstrations.
The technique, called failure-guided experience retrieval fine-tuning, retrieves segments from successful trajectories based on the context of failures and uses them for supervised updates. Across five real-world manipulation tasks, the authors report success rates of 93.3% to 99.2%, measured over 120 trials per task on robots that were not used to collect data.
On multi-stage phone packaging, a fleet of 96 robots raised success from 79.2% to 98.3%. With collection time per robot held fixed, larger fleets generally performed better across the fleet sizes tested.
This is a preprint and has not been peer reviewed. The results are the authors' own, and the abstract page does not name the robot model or the affiliations.
Sources
- arXiv Primary source